Overview
Across two competition cycles, I was a part of 3–4 person teams building autonomous robots for sensor-based navigation challenges. This included a garbage-collection robot and a fire-fighting robot, both judged on accuracy, line-following, and task-specific performance.
What I Worked On
- As the person with the most background experience, directed teams of 3–4, under the supervision of an advisor, through the full build cycle: design, wiring, programming, and testing
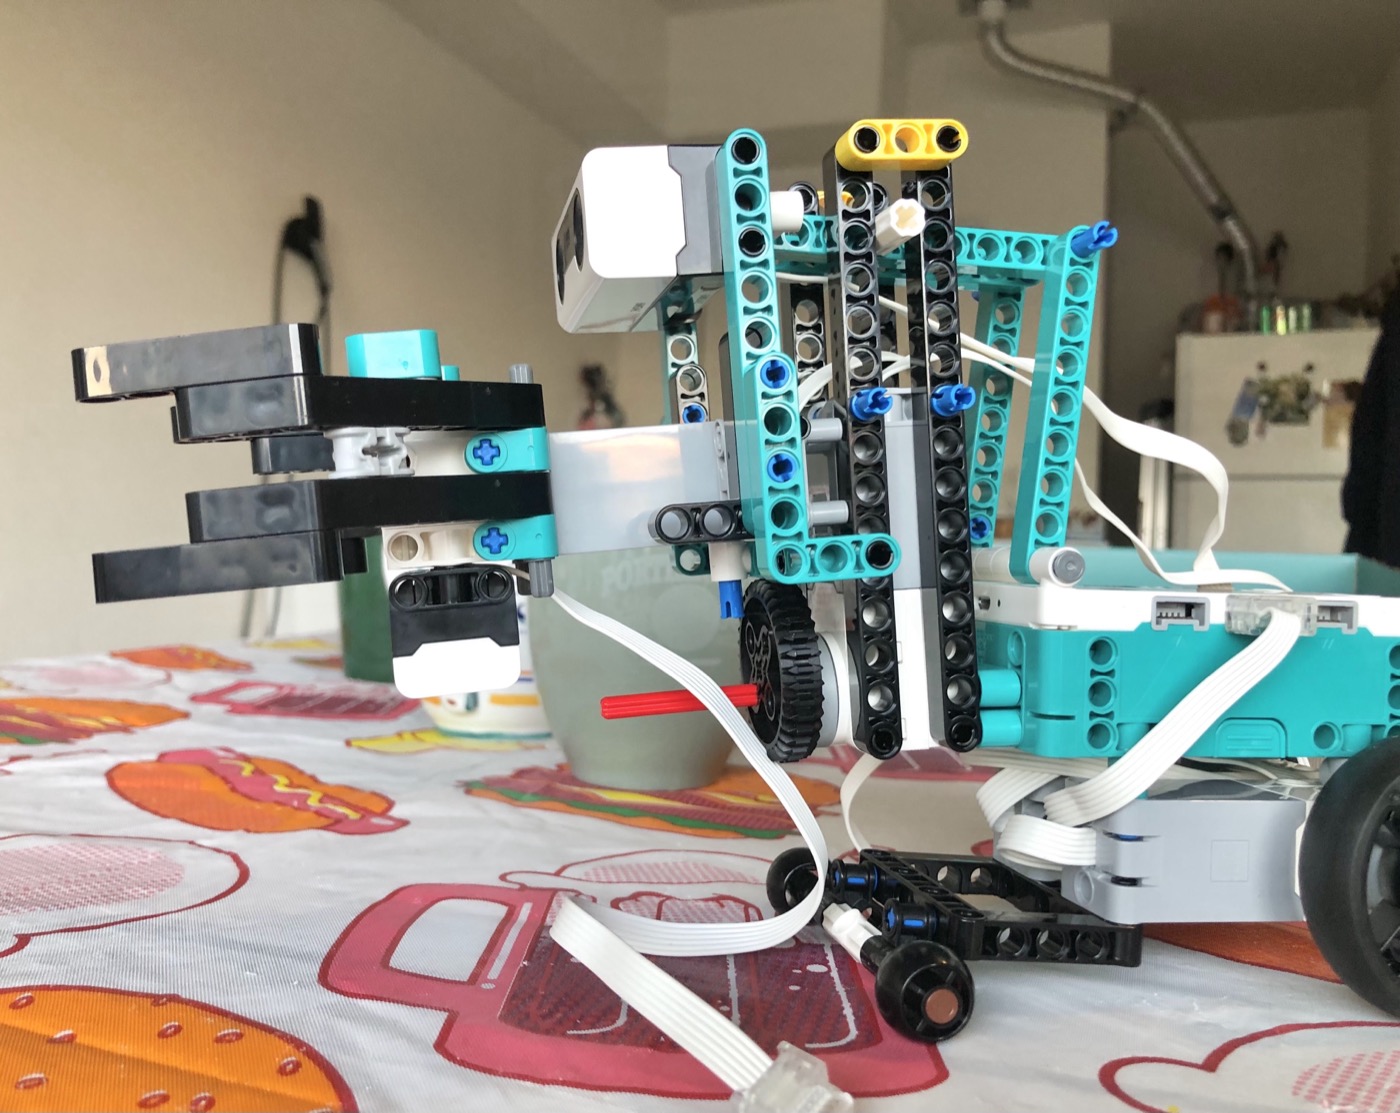
- Structured navigation using Arduino and Python. The fire-fighting robot utilized a thermal sensor to detect and sense when the (candle) fire was fully put out using the fan mounted onto the robot. Next time around, the garbage-truck bot used our customized claw mechanism to lift garbage cans and dump them in the dumpster area.
- Implemented maze-solving algorithms to handle unpredictable competition courses
- Iterated on sensor calibration and control logic through repeated test runs ahead of competition day, making sure the color sensor allowed the robot to stay following maze lines
Why It Mattered
With sensor-based navigation, a robot either reliably reads its environment and reacts correctly, or it doesn't. Getting the thermal and color sensor calibration right, combined with maze-solving logic that could handle courses it hadn't seen before, is what separated a robot that worked in practice from one that only worked in our garage. Both robots placed 1st and 2nd in their respective categories, and I had the privilege of succesfully getting a taste of the robotics realm.