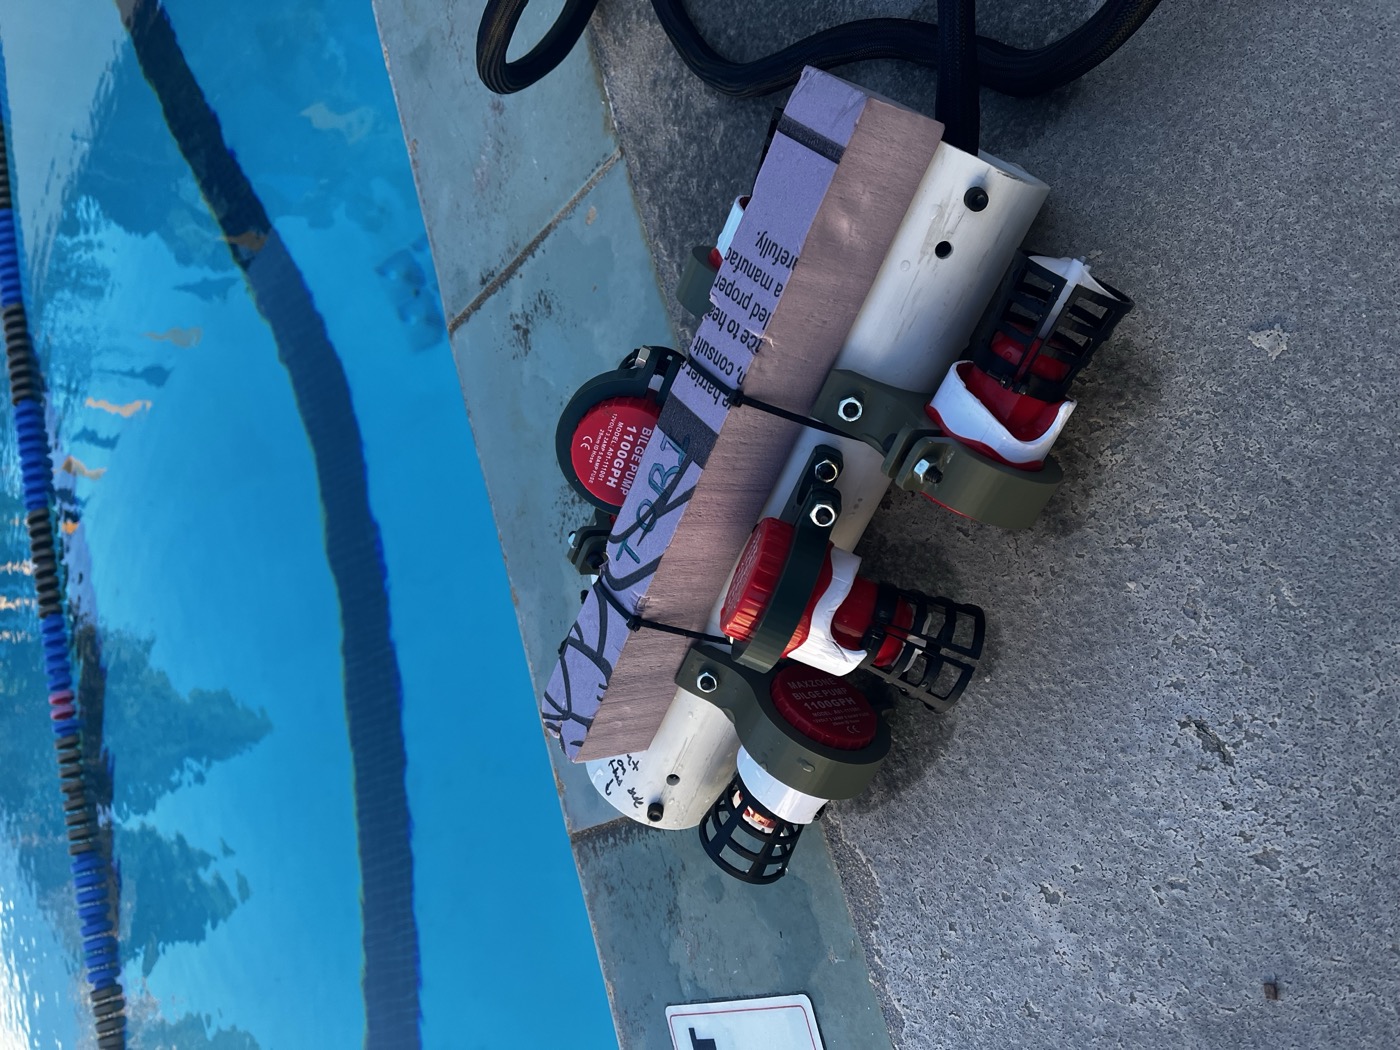
Overview
As mechanical lead for our 3 person team, I handled the design, manufacturing, and assembly of a remotely operated underwater vehicle (ROV), built to navigate obstacle courses and demonstrate controlled movement across four degrees of freedom.
What I Worked On
- Designed custom mounting systems for thrusters, the onboard camera, and the tethering system in CAD
- Manufactured every mechanical component of the vehicle, from mounts to housings
- Worked on electrical assembly, including soldering connections for thrusters, camera, and sensor wiring
Why It Mattered
In our team, we were down to 2 people handling programming and electrical, and 1 person working on mechanical. With my previous interest in robotics and mechanical assembly, I volunteered. This was my first time 3D modeling, so learning about 3D design and all the nitty gritty things involved with it through trial and error, like tolerance and strain, dropped me into an infinite pool of opportunity. With endless revisions of our thruster mounts, drill guides, and other components, we were relieved to see a working bot come to fruition, and I was grateful to have acquired such a door opening skill. Ultimately, our combined efforts saw our vehicle, happily named TORI by me, complete complex obstacle courses successfully.